1
c2d
Purpose
16c2d
Discretize continuous-time systems
Syntax
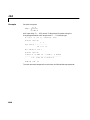
sysd = c2d(sys,Ts)
sysd = c2d(sys,Ts,method)
[sysd,G] = c2d(sys,Ts,method)
Description
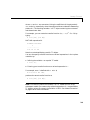
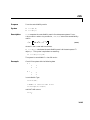
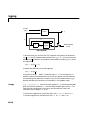
sysd = c2d(sys,Ts) discretizes the continuous-time LTI model sys using
zero-order hold on the inputs and a sample time of Ts seconds.
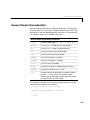
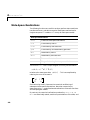
sysd = c2d(sys,Ts,method) gives access to alternative discretization
schemes. The string method selects the discretization method among the
following:
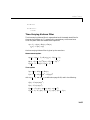
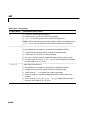
'zoh'
Zero-order hold. The control inputs are assumed piecewise
constant over the sampling period Ts.
'foh'
Triangle approximation (modified first-order hold, see [1], p.
151). The control inputs are assumed piecewise linear over
the sampling period Ts.
'tustin'
Bilinear (Tustin) approximation.
'prewarp'
Tustin approximation with frequency prewarping.
'matched'
Matched pole-zero method. See [1], p. 147.
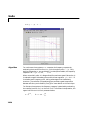
Refer to “Continuous/Discrete Conversions of LTI Models” in Chapter 3 for
more detail on these discretization methods.
c2d supports MIMO systems (except for the 'matched' method) as well as LTI
models with delays with some restrictions for 'matched' and 'tustin'
methods.
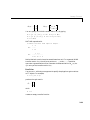
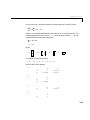
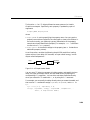
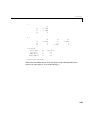
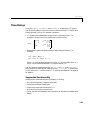
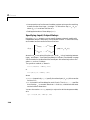
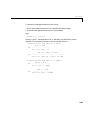
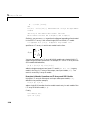
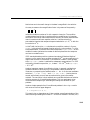
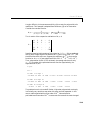
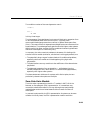
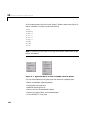
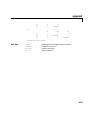
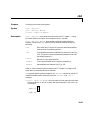
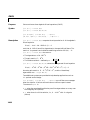
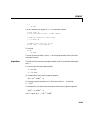
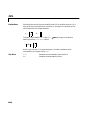
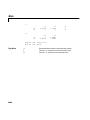
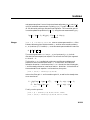
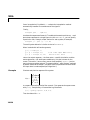
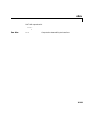
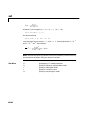
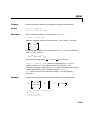
[sysd,G] = c2d(sys,Ts,method) returns a matrix G that maps the continuous
initial conditions x 0 and u 0 to their discrete counterparts x [ 0 ] and u [ 0 ]
according to
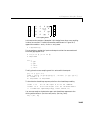
x[ 0 ] = G ⋅
x0
u0
u[ 0 ] = u0
16-27