1
Appendix 6 Explanation of terms
A ACCELERATION
ABSOLUTE SYSTEM
Refers to the cam's dimensionless acceleration
rate.
The dimensionless acceleration rate is the
dimensionless speed differentiated by the
dimensionless time.
The maximum value is expressed as Am.
Refer to the term "Am".
Refer to the term "V".
This is one system for expressing a positioning
address.
This system uses 0 as a reference, and
expresses the address as the distance from 0.
The positioning direction is automatically
determined, even when it is not designated.
The other address system is the increment
system.
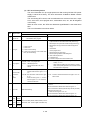
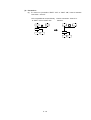
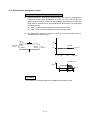
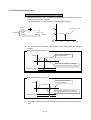
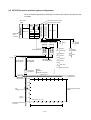
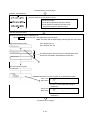
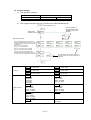
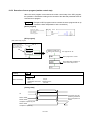
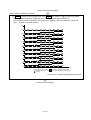
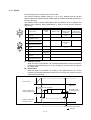
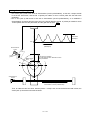
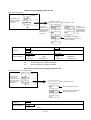
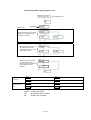
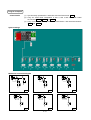
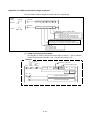
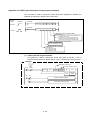
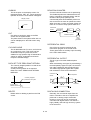
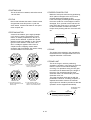
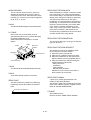
ABSOLUTE ENCODER
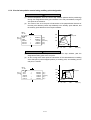
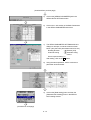
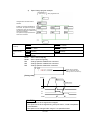
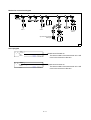
This is a absolute position detector that
enables the angle data within 1 motor rotation
to be output to an external destination.
Absolute encoders are generally able to output
360° in 8 to 12 bits.
Incremental encoders have a disadvantage in
that the axis position is lost when a power
failure occurs. However, with absolute
encoders, the axis position is not lost even
when a power failure occurs.
Various codes such as a binary code and BCD
code can be output.
Absolute encoders are more expensive, more
accurate, and larger than incremental
encoders. Refer to "ENCODER".
(1)
No. 2
(2)
(3)
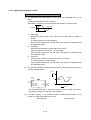
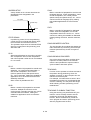
ACCELERATION
Acceleration is obtained from speed
differentiated by time and refers to the change
rate of speed. Acceleration is in proportion to
stress. Refer to the term A
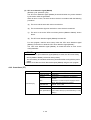
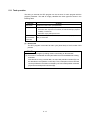
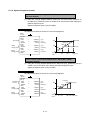
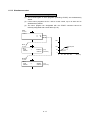
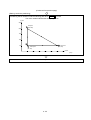
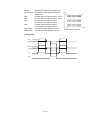
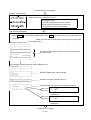
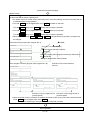
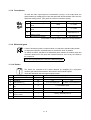
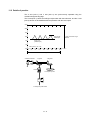
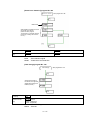
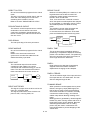
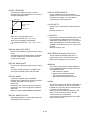
ACCELERATION TIME
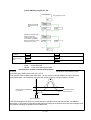
Fixed slit
Light-emitting diode
2
21
2 34
2
Phototransistor
24
23
2
2
Rotating 2 1
20
axis
No. 3
(1) to (3) indicate the operation order.
0
Slit disk
No. 1
0
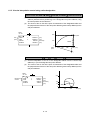
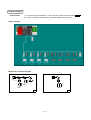
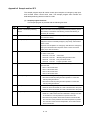
Time for the full speed to be reached from the
stopped state with the motion controller.
The parameter acceleration/deceleration refers
to the time to reach the speed limit value, and
if the set speed is low, the time will be
proportionally shorter.
This is determined by the machine's inertia,
motor torque and load's resistance torque, etc.
Full speed = Speed limit value
Binary code
Speed
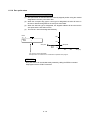
ABSOLUTE POSITION SYSTEM
If zero point return is carried out once after
starting up the positioning control devices, the
current value will be backed up with a battery
when the power is turned OFF, and the
machine deviation will be compensated even if
it occurs.
Thus, zero point return is not required after the
power is turned ON again.
A servomotor with absolute position detector
and a compatible servo amplifier are required
to structure this system.
Time
0
Acceleration time
AC MOTOR DRIVE UNIT
The AC motor drive unit is a built-in type servo
amplifier that can drive one connected
servomotor.
A - 38