1
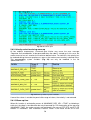
5.1.6 Safety orientated parameters
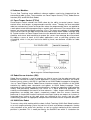
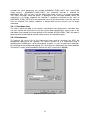
To move the robot in the teaching mode it is required that the key switch is set to automatic
mode and that the enabling switch is pressed.
If the Safe teaching mode is not activated, safety monitoring is deactivated as well and the
robot moves as a conventional robot in automatic mode.
The option Safe Robot is parameterized as follows:
• maximum velocity is set to 250 mm/s; a danger analysis may allow other limitations
• maximum acceleration is set to 200°/s²
• standstill monitoring is set to 200 ms (realised with a Safety-SPS: the signal of the
KGD acknowledgement is transferred with a delay of 200 ms to the Safe RDW)
5.1.7 Intended usage
The intended usage of the robot in the safe teaching mode is moving the robot with a force
torque sensor mounted on the tool flange. Possible applications are i.e. the intuitive teaching
of the robot by manual movement.
If the robotic sell provides special safety areas for the operator when the robot moves in
automatic mode, an acknowledgement button has to be installed within this area to start a
programmed movement.
The operator has to have a good overview of the cell to ensure that no persons are in the
danger zone.
5.2 The Safe Robot technology
5.2.1 Introduction
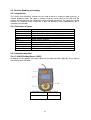
KUKA Safe Robot is an axis range monitoring systems. It consists of software and hardware
components. Its functions are the safe evaluation of the actual position, the cyclical
monitoring of the reference position and a cyclical brake test. It can be connected to external
safety logic.
5.2.1.1 Features
•
•
•
•
•
•
•
•
Monitoring of up to 10 user-defined ranges
Ranges can be combined
Shorter reaction times and braking distances
Safe inputs and outputs of a redundant design
Safe reduced axis-specific velocity and acceleration
Safe, reduced Cartesian velocity monitoring at the mounting flange
Safe operational stop
Safe stop via Electronic Safety Circuit with safe disconnection of the drives
5.2.1.2 Areas of application
•
•
•
•
•
Human-robot cooperation
Use of robots in medical and laboratory technology
Reduction of floor space requirements within a system
Direct loading of workpieces without an intermediate support
Replacement of conventional axis range monitoring systems
5.2.2 Definitions of terms
Axis range: The Axis range is the range in which an axis can be moved. It is measured in
degrees or millimetres. It is required to define the axis range for every axis that is to be
monitored.
Axis limit: The upper limit and the lower limit of an axis define its axis range.
Inversion: The inversion defines the nature of an axis range. It can be defined as a danger
zone or a safety zone.
14