1
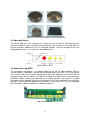
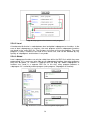
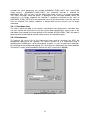
Fig. 28 All FOLDs open
5.8.9 Velocity reduction during warm-up
At low ambient temperatures, increased gear friction may cause the error message
“Regulator limit exceeded Ax” to be generated when the robot is started up. In this case, the
motor current of an axis reaches the maximum defined value. To avoid this, the velocity can
be reduced during the warm-up phase as soon as the motor current reaches a defined value.
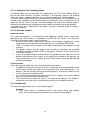
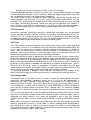
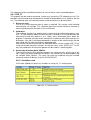
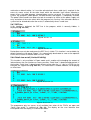
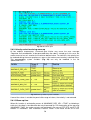
The corresponding system variables (Fig. 29) can only be modified in the file
“$MACHINE.DAT”.
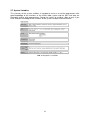
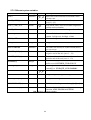
Fig. 29 Warm-up related system variables
If one of the values is outside the permissible range of values, the velocity is not reduced.
5.8.10 Warm-up time
When this function is activated by means of “$WARMUP_RED_VEL = TRUE”, or following a
cold start, the robot is considered to be not yet warmed up. For the duration of the warm-up
($WARMUP_TIME), the motor currents are monitored in the case of PTP-PTP and PTP-CP
motions in “Automatic” and “Automatic External” mode. If the motor current of an axis
50