1
Revision 3.10, January 2005
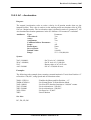
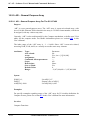
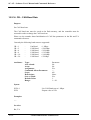
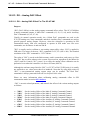
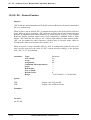
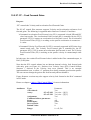
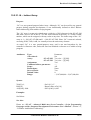
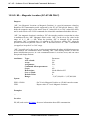
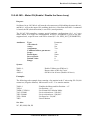
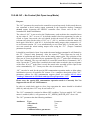
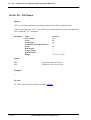
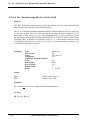
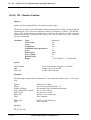
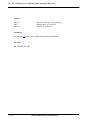
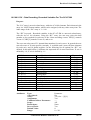
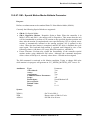
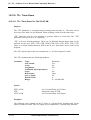
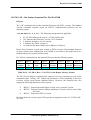
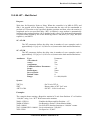
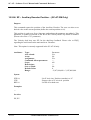
10.5.2. AC – Acceleration
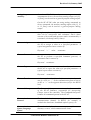
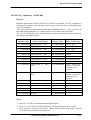
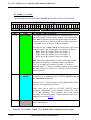
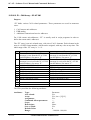
Purpose:
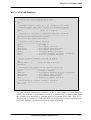
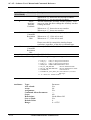
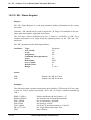
The normal Acceleration value to cruise velocity in all motion modes (that use the
internal Profiler). This value is used to set the motion profile acceleration value in PTP,
JOG etc. Motion modes. The Acceleration value is defined in units of: [counts/sec2]. All
Acceleration/Deceleration parameters in the SC-4M has a 256 counts/sec2 resolution.
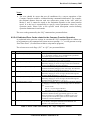
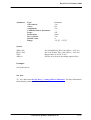
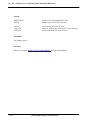
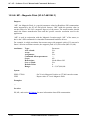
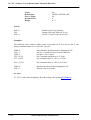
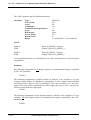
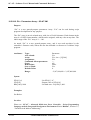
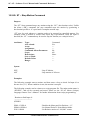
Attributes:
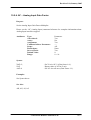
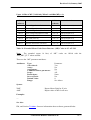
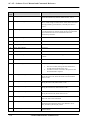
Type:
Axis related:
Array:
Assignment:
Command Allows Parameter:
Scope:
Restrictions:
Save to Flash:
Default Value:
Range:
Parameter.
Yes.
No.
Yes.
---.
All.
None.
Yes.
100,000.
512 ÷ 120,000,000.
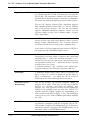
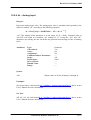
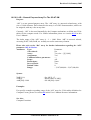
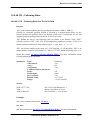
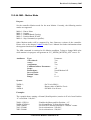
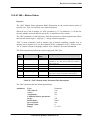
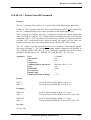
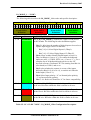
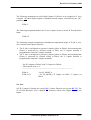
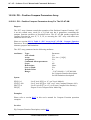
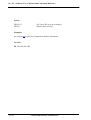
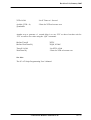
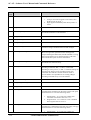
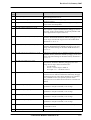
Syntax:
XAC=1000000;
WAC=1000000;
ZAC
AAC=240000
‘ Set X Axis AC=1,000,000.
‘ Set W Axis AC=1,000,000.
‘ Report value of AC for Z axis.
‘ Set AC=250,000 all axes.
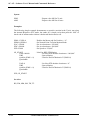
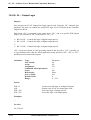
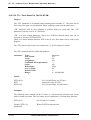
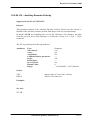
Examples:
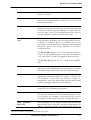
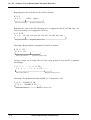
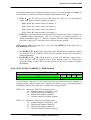
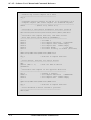
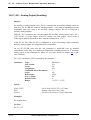
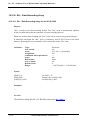
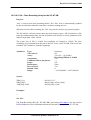
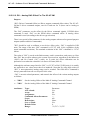
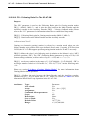
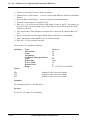
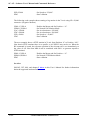
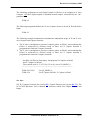
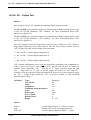
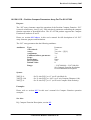
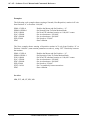
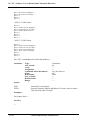
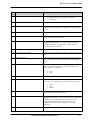
The following code example shows starting a normal motion in X axis from Position “0”
to Position “100,000”, using Speed and Acceleration values.
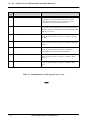
XMO=1;XPS=0
XMM=0;XSM=0
XAP=100000
XAC=250000
XDC=500000
XSP=25000
XBG
‘ Enables the Motor and Set Position = “0”.
‘ Set Normal Point To Point Motion Mode.
‘ Set Next PTP absolute location to “100,000” counts.
‘ Set Acceleration to “250,000”.
‘ Set Acceleration to “500,000”.
‘ Set Speed to “25,000”.
‘ Start a Motion
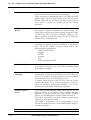
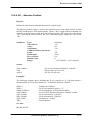
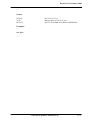
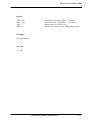
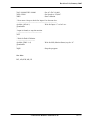
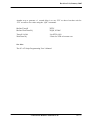
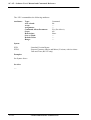
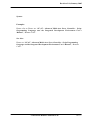
See Also:
DC, DL, SP, BG
Control and Robotics Solutions Ltd.
10-15