1
Technical Document:QCI-TD051
QuickSilver Controls, Inc.
Torque Modes w/ Anti-Hunt Enabled
Torque Modes w/ Anti-Hunt Enabled
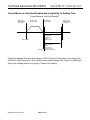
Open Loop
Holding Mode
“Anti-Hunt”
Closed Loop
Moving Mode
Closed Loop
Moving Mode
Closed Loop
Holding Mode
Open Loop
Holding Mode
“Anti-Hunt”
Time
ERL:Delay To
Holding Time
Change from
Moving to
Holding Torque
Start of Move
Settling
AHD:Anti-Hunt
Delay
Change from
Closed Loop to
Open Loop Torque
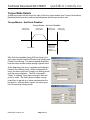
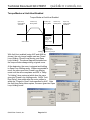
With Anti-Hunt enabled (using AHC and AHM as
shown), the only torque modes used are Closed
Loop Holding, Closed Loop Moving, and Open
Loop Holding. The above diagram illustrates how
the torque modes change during a typical move.
At the beginning, the servo is stopped and holding
in Open Loop Holding mode. When commanded to
move, the servo goes into Closed Loop Moving
mode until the move completes and ERL’s “Delay
To Holding” timer expires at which time the servo
goes into Closed Loop Holding mode. AHD’s “AntiHunt Delay” timer starts after the motor settles to
within the “Closed to Open” limits specified by AHC. After
the Anti-Hung Delay timer expires, the servo goes into Open
Loop Holding mode.
QuickSilver Controls, Inc.
Page 4 of 11