1
58
AX DRIVE USER GUIDE
Determining
Backlash
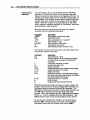
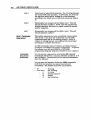
You can measure the actual backlash with the following
procedure. The idea is to move in one direction, stop, and
make a series of one-step moves in the opposite direction. No
change in encoder position occurs while the indexer takes up
the backlash. The number of motor steps counted before any
encoder counts are received is the measure of the backlash.
NOTE: When the en.ccxier is mounted directly to the motor,
this is mainly a magnetic backlash (or hysteresis), othenvise.
gear backlash is also measured.
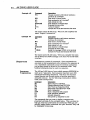
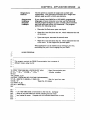
Move the motor in one direction and clear the position
counters with the following commands.
Command
FSB0
MN
A10
V1
06400
G
PZ
Description
Sets indexer to motor step mode
Sets Mode normal
Sets acceleration to 10 revslsec 2
Sets velocity to 1 rps
Sets distance to 6400 steps
Executes the move (Go)
Sets absolute pOSition counter to zero
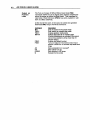
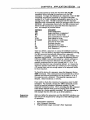
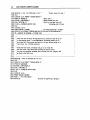
Now execute a series of one-step moves and report both motor
and encoder position each time:
Command
01
PS
L
G
1LF
1PR
T1.0
1LF
1PX
T1.0
N
C
Description
Sets distance to 1 step
Pauses execution of the following commands
until the indexer receives the Continue (C)
command
Causes the sequence to repeat
Executes the move (Go)
Sends a line feed
Reports absolute motor position in motor steps
Pauses the motor for 1 second
Sends a line feed
Reports the number of encoder pulses (steps)
that the encoder has received since the Position
Zero (PZ) command was issued
Pauses the motor for 1 second
Ends the loop
Clears pause and executes the move
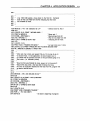
While this command string is running, you may compare the
position reports from the Position Report (PR) command and
the Report Absolute Encoder POSition (PX) command. The
IPR report represents the number of motor steps traveled, and
the IPX report represents the number of encoder steps
traveled. When the response from the IPX command changes
from 0 to I, note the response from the IPR command. This
IPR command report is the actual backlash of your system.
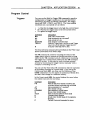
To use the AX's stall detection function, set the Dead Band
Window (DW) command equal to the value of the backlash
determined above and then Enable Stall Detect (FSH1).