1
4.3
4.4
4.19
4.20
4.21
The obstacle inflation and path planning results of CostMap. . . . . . . . . . . . . . . . . . .
How inflation is used to determine occupancy. Image courtesy of the CostMap 2D wiki(ROS,
2010). . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
Increased obstacle inflation and resulting path planning of CostMap. . . . . . . . . . . . . . .
Portion of the code used to connect to the GPS client. . . . . . . . . . . . . . . . . . . . . . .
Portion of the code used to send GPS goals to the path planner. . . . . . . . . . . . . . . . .
Parameters used to constrain the path planner. . . . . . . . . . . . . . . . . . . . . . . . . . .
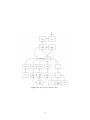
The RXGraph output of 2012 Prometheus. . . . . . . . . . . . . . . . . . . . . . . . . . . . .
Results of multiple trials of GPS Waypoint navigation. . . . . . . . . . . . . . . . . . . . . . .
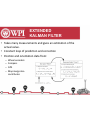
Operation of the extended Kalman Filter. Image courtesy of Welch & Bishop (1995) . . . . .
The state vector of the system: GPS gives X and Y, Phi is given by the compass . . . . . . .
Measurement noise covariance matrix R . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
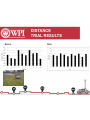
Distance tests for the encoder and compass . . . . . . . . . . . . . . . . . . . . . . . . . . . .
System noise covariance matrix Q . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
Measurement matrix H . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
Implementation of the EKF in ROS . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
LabVIEW Logging of Raw and Filtered data from encoders and Compass (Akmanalp et al.,
2011) . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
LabVIEW logging of Raw and Filtered Path from Sensor Data around Atwater Kent . . . . .
The Hand Drawn Circle on the Ground . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
EKF, GPS, and Encoder Results . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . . .
5.1
5.2
5.3
5.4
5.5
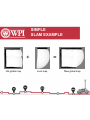
Demonstration course with lines . . . . . . . . . . . . . .
Demonstration course with cones and lines . . . . . . . . .
Demonstration course with cones, lines and goals . . . . .
Prometheus successfully avoiding a line with a goal on the
Prometheus demonstrating its ability to locate obstacles .
.
.
.
.
.
48
49
49
51
51
6.1
Prometheus navigating during the demonstration in Institute Park . . . . . . . . . . . . . . .
52
B.1 Description of the remote control and it’s various modes of operation. . . . . . . . . . . . . .
59
4.5
4.6
4.7
4.8
4.9
4.10
4.11
4.12
4.13
4.14
4.15
4.16
4.17
4.18
iv
. . . . . .
. . . . . .
. . . . . .
other side
. . . . . .
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
.
37
37
38
38
38
39
39
40
42
42
43
43
44
44
44
45
45
45
46